


|
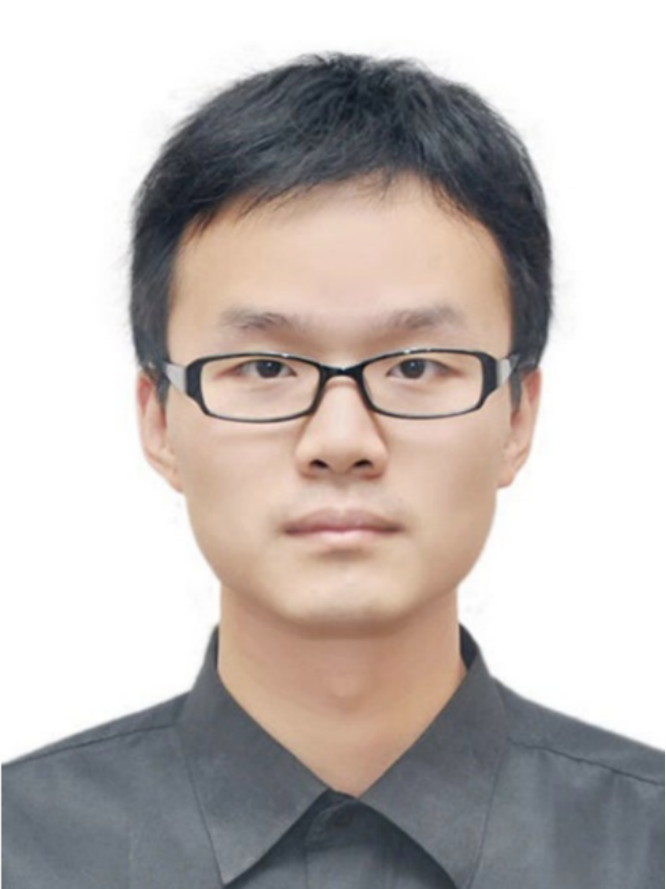
姓名:蒋周翔 教授,硕士生导师 电子邮箱:jiangzxoy@163.com 办公地址:北京信息科技大学沙河校区工学楼B533 |
所在系部及研究方向
所在系部:机械工程及自动化系
研究方向:机器人误差补偿,特种机器人技术
工作履历及教育背景
2025年1月–现今:北京信息科技大学机电工程学院,教授
2017年6月–2024年12月:北京信息科技大学机电工程学院,副教授
2012年9月–2016年6月:华中科技大学机械电子工程专业博士学位
2008年9月–2011年6月:中国地质大学(北京)机械设计制造及其自动化专业硕士学位
2004年9月–2008年6月:北京信息科技大学机械设计制造及其自动化专业学士学位
承担教学任务
本科生课程:《机械设计》、《机械设计基础》、《优化设计》
研究生课程:智能机械装备设计、分析及应用课程
承担科研项目
1. 2022-2025:国家自然科学基金面上项目,主持
2. 2019-2021:国家自然科学基金青年基金项目,主持
3. 2019-2020:北京市教委科研计划面上项目,主持
主要科研成果
1. 发表学术论文:
[1] Rui Liu, Zhouxiang Jiang et. al.; Cable-Driven hyper-redundant manipulator with pitch-twist joints: mechatronic design, kinematics analysis, and prototype, Journal of Field Robotics, 2026. (SCI)
[2] Yuchen Zhao, Zhouxiang Jiang et. al.; Structural design and experimentation of a reconfigurable extendable cable-driven manipulator, IEEE Robotics and Automation Letters, 2025. (SCI)
[3] Zhouxiang Jiang et. al.; Accurate relative measurement of multitarget poses by monocular vision for nonmodel-based real-time calibration of industrial robot, Measurement, 2024. (SCI)
[4] Zhouxiang Jiang et. al.; Accurate kinematic calibration of a six-DoF serial robot by using hybrid models with reduced dimension and minimized linearization errors, Industrial Robot-The International Journal of Robotics Research and Application, 2024. (SCI)
[5] Yixuan Guo, Zhouxiang Jiang et. al.; A calibration method for tool frame in the three-dimensional measurement system based on R-test, International Journal of Advanced Manufacturing Technology, 2023. (SCI)
[6] Yixuan Guo, Zhouxiang Jiang et. al.; A distance calibration method for kinematic parameters of serial industrial robots considering the accuracy of relative position, Measurement, 2022. (SCI)
[7] Zhouxiang Jiang et. al.; A new calibration method for joint-dependent geometric errors of industrial robot based on multiple identification spaces, Robotics and Computer-Integrated Manufacturing, 2021. (SCI)
[8] Zhouxiang Jiang et. al.; Elasto-geometrical calibration of six-DOF serial robots using multiple identification models, Mechanism and Machine Theory, 2021. (SCI)
[9] Zhouxiang Jiang et. al.; Stable calibrations of six-DOF serial robots by using identification models with equalized singular values, Robotica, 2021. (SCI)
[10] Zhouxiang Jiang et. al.; Observability index optimization of robot calibration based on multiple identification spaces, Autonomous Robots, 2020. (SCI)
[11] Zhouxiang Jiang et. al.; Optimization of fixture flexibility for irregular geometries of workpiece based on metamorphic mechanisms, The International Journal of Advanced Manufacturing Technology, 2019. (SCI)
2. 授权发明专利
[1] 一种具有扭转关节的多自由度绳驱蛇形机械臂, 2026
[2] 基于进退式内骨架与伸缩式臂体外壳的绳驱蛇形机械臂, 2025
[3] 柔性超冗余机械臂标定方法、系统、存储介质及计算设备, 2025
[4] 基于分布式位姿采集和模型降维的机械臂标定方法及装置, 2025
[5] 基于双目视觉和深度学习的机械臂不停工实时标定方法及装置, 2023
[6] 基于多目标视觉测量和机器学习的机械臂无模型实时标定方法及装置,2023
奖励与荣誉
1. 2025年度中国自动化学会科学技术进步奖二等奖
2. 2024年度第九届“中国好设计”银奖
3. 2021年度校青年教师基本功大赛三等奖、最受学生欢迎奖、机电学院教学新星
4. 2018、2021 年度机电学院学术标兵
5. 北京高校教师教学创新大赛优秀奖
6. 第十七届“创新杯”大学生学术科技创新竞赛优秀指导教师奖